Example: Fluid Simulation
Objective
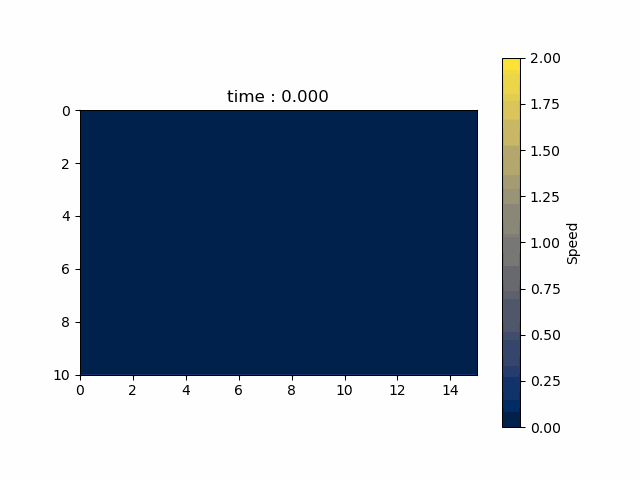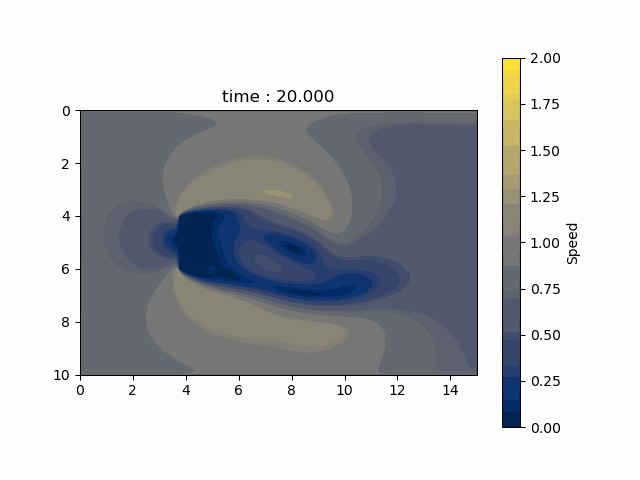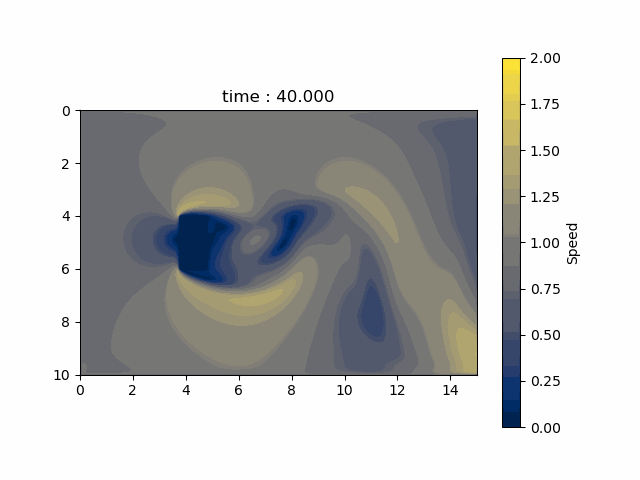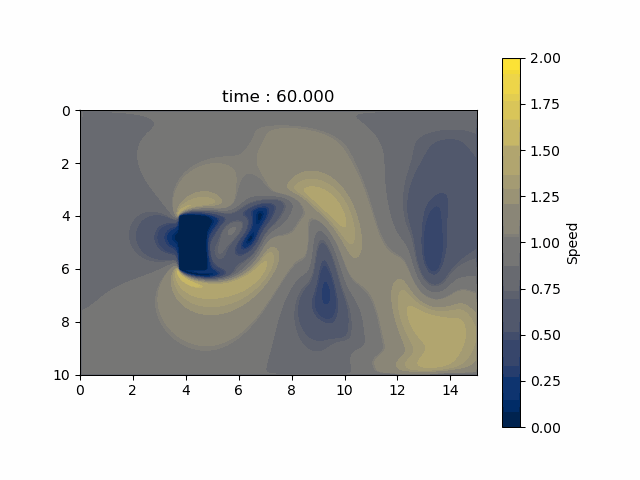
We will visualize a Karman vortex street by solving the Navier-Stokes equations.
Physics
Continuity Equations
\nabla \cdot \boldsymbol{u} = 0
Chorin’s Projection Method
We use the Chorin’s projection method [1] [2] for solving the Navier-Stokes equations. For details of the method, please refer to the following lists.
In this example, the following computation flow will be repeated for the number of time steps.
Determine the temporary flow velocity \boldsymbol{u}^{\star}
\begin{equation} \boldsymbol{u}^{\star}=\boldsymbol{u}^{n}-\Delta t(\boldsymbol{u}^n \cdot \nabla)\boldsymbol{u}^{n}+\frac{\Delta t}{Re}\nabla^2\boldsymbol{u}^{n} \tag{A} \end{equation}
where \boldsymbol{u}^{n} is the flow velocity at the time step n.
Determine the pressure p^{n+1} by solving the Poisson equation
\begin{equation} \nabla^2 p^{n+1} = \frac{\nabla \cdot \boldsymbol{u}^{\star}}{\Delta t} \tag{B} \end{equation}
To solve this Poisson equation, we use the Jacobi method.
Determine the flow velocity \boldsymbol{u}^{n+1}
\begin{equation} \boldsymbol{u}^{n+1} = \boldsymbol{u}^{\star} - \Delta t \nabla p^{n+1} \tag{C} \end{equation}
Boundary Conditions
Boundary |
Flow Velocity |
Pressure |
|---|---|---|
Injection(x=0, y=0, y=LY) |
0.9, 0.1 |
0 |
Leak(x=LX) |
\frac{\partial \boldsymbol{u}}{\partial x}=0 |
\frac{\partial p}{\partial x}=0 |
Object Surface |
(0, 0) |
\frac{\partial p}{\partial x}=0, \frac{\partial p}{\partial y}=0 |
Object Inner |
(0, 0) |
0 |
Program
import nlcpy as vp
from matplotlib import pyplot as plt
from matplotlib import animation

Re = 100
DX = .01
DY = .01
DT = .002
NT = 30000
PLOT_INTERVAL = 500
LX = 15.
LY = 10.
NX = int((LX // DX) + 1)
NY = int((LY // DY) + 1)
U_INJ = .9
V_INJ = .1

MAX_ITER_JACOBI = 50
TOL_JACOBI = 1e-3

OBJ_X_BEGIN = int(NX // 4)
OBJ_X_END = int(NX // 4 + NX // 15)
OBJ_Y_BEGIN = int(NY // 2 - NY // 10)
OBJ_Y_END = int(NY // 2 + NY // 10)
OBJ_X_IND = slice(OBJ_X_BEGIN, OBJ_X_END + 1)
OBJ_X_INNER_IND = slice(OBJ_X_BEGIN + 1, OBJ_X_END)  # exclude surface
OBJ_Y_IND = slice(OBJ_Y_BEGIN, OBJ_Y_END + 1)
OBJ_Y_INNER_IND = slice(OBJ_Y_BEGIN + 1, OBJ_Y_END)  # exclude surface

DTYPE = 'float32'


def init():
    u = vp.sca.create_optimized_array((NY, NX), dtype=DTYPE)  # x-axial velocity
    v = vp.sca.create_optimized_array((NY, NX), dtype=DTYPE)  # y-axial velocity
    p = vp.sca.create_optimized_array((NY, NX), dtype=DTYPE)  # pressure
    u_tmp = vp.sca.create_optimized_array((NY, NX), dtype=DTYPE)
    v_tmp = vp.sca.create_optimized_array((NY, NX), dtype=DTYPE)
    p_tmp = vp.sca.create_optimized_array((NY, NX), dtype=DTYPE)
    s = vp.sca.create_optimized_array((NY, NX), dtype=DTYPE)  # right hand side of poisson
    # injection
    u[1:-1, 0] = U_INJ
    v[1:-1, 0] = V_INJ
    u[0, 1:-1] = U_INJ
    v[0, 1:-1] = V_INJ
    u[-1, 1:-1] = U_INJ
    v[-1, 1:-1] = V_INJ
    u_tmp[...] = u
    v_tmp[...] = v
    return u, v, p, u_tmp, v_tmp, p_tmp, s


def bnd_velocity(u, v, u_tmp, v_tmp):
    u[OBJ_Y_IND, OBJ_X_IND] = 0
    v[OBJ_Y_IND, OBJ_X_IND] = 0
    u[1:-1, -1] = u_tmp[1:-1, -2]  # du/dx = 0
    v[1:-1, -1] = v_tmp[1:-1, -2]  # dv/dx = 0


def bnd_pressure(p, p_tmp):
    p[OBJ_Y_INNER_IND, OBJ_X_INNER_IND] = 0
    p[OBJ_Y_IND, OBJ_X_BEGIN] = p_tmp[OBJ_Y_IND, OBJ_X_BEGIN - 1]  # dp/dx = 0
    p[OBJ_Y_IND, OBJ_X_END] = p_tmp[OBJ_Y_IND, OBJ_X_END + 1]      # dp/dx = 0
    p[OBJ_Y_BEGIN, OBJ_X_IND] = p_tmp[OBJ_Y_BEGIN - 1, OBJ_X_IND]  # dp/dy = 0
    p[OBJ_Y_END, OBJ_X_IND] = p_tmp[OBJ_Y_END + 1, OBJ_X_IND]      # dp/dy = 0
    p[1:-1, -1] = p_tmp[1:-1, -2]  # dp/dx = 0


def set_temporary_velocity_kernel(u_w1, v_w1, u_w2, v_w2, c, kernels):
    du_w1, dv_w1, du_w2, dv_w2 = vp.sca.create_descriptor((u_w1, v_w1, u_w2, v_w2))

    desc_u = (
        c[0] * du_w1[0, 0] +
        c[1] * (u_w1[1:-1, 1:-1] * (du_w1[0, 1] - du_w1[0, -1])) +
        c[2] * (v_w1[1:-1, 1:-1] * (du_w1[1, 0] - du_w1[-1, 0])) +
        c[3] * (du_w1[0, 1] + du_w1[0, -1]) +
        c[4] * (du_w1[1, 0] + du_w1[-1, 0])
    )
    kern_u = vp.sca.create_kernel(desc_u, desc_o=du_w2[0, 0])
    kernels['temporary_u'] = kern_u

    desc_v = (
        c[0] * dv_w1[0, 0] +
        c[1] * (u_w1[1:-1, 1:-1] * (dv_w1[0, 1] - dv_w1[0, -1])) +
        c[2] * (v_w1[1:-1, 1:-1] * (dv_w1[1, 0] - dv_w1[-1, 0])) +
        c[3] * (dv_w1[0, 1] + dv_w1[0, -1]) +
        c[4] * (dv_w1[1, 0] + dv_w1[-1, 0])
    )
    kern_v = vp.sca.create_kernel(desc_v, desc_o=dv_w2[0, 0])
    kernels['temporary_v'] = kern_v


def set_poisson_kernel(u, v, p_w1, p_w2, s, c1, c2, kernels):
    du, dv, dp_w1, dp_w2, ds = vp.sca.create_descriptor((u, v, p_w1, p_w2, s))

    desc_right = (
        c1[0] * (du[0, 1] - du[0, -1]) +
        c1[1] * (dv[1, 0] - dv[-1, 0])
    )
    kern_right = vp.sca.create_kernel(desc_right, desc_o=ds[0, 0])
    kernels['poisson_right_hand'] = kern_right

    desc_p = (
        c2[0] * (dp_w1[0, 1] + dp_w1[0, -1]) +
        c2[1] * (dp_w1[1, 0] + dp_w1[-1, 0]) +
        c2[2] * ds[0, 0]
    )
    kern_p = vp.sca.create_kernel(desc_p, desc_o=dp_w2[0, 0])
    kernels['poisson_solve_p'] = kern_p


def set_next_velocity_kernel(u_w1, v_w1, p, u_w2, v_w2, c, kernels):
    du_w1, dv_w1, dp, du_w2, dv_w2 = \
        vp.sca.create_descriptor((u_w1, v_w1, p, u_w2, v_w2))

    desc_u = (
        du_w1[0, 0] + c[0] * (dp[0, 1] - dp[0, -1])
    )
    kern_u = vp.sca.create_kernel(desc_u, desc_o=du_w2[0, 0])
    kernels['next_velocity_u'] = kern_u

    desc_v = (
        dv_w1[0, 0] + c[1] * (dp[1, 0] - dp[-1, 0])
    )
    kern_v = vp.sca.create_kernel(desc_v, desc_o=dv_w2[0, 0])
    kernels['next_velocity_v'] = kern_v


def draw(u, v, ax, ts):
    plt.cla()
    ax.set_title('time : {:.3f}'.format(ts * DT * PLOT_INTERVAL))
    ax.imshow(
        vp.sqrt(u * u + v * v).get(),
        vmin=0, vmax=2.,
        cmap='cividis',
        extent=[0, LX, LY, 0]
    )


def cfd():
    u_w1, v_w1, p_w1, u_w2, v_w2, p_w2, s = init()

    coef1 = [
        1 - (2 * DT / Re) * (1 / (DX * DX) + 1 / (DY * DY)),
        - DT / (2 * DX),
        - DT / (2 * DY),
        DT / (Re * DX * DX),
        DT / (Re * DY * DY)
    ]
    coef2 = [
        1 / (2 * DT * DX),
        1 / (2 * DT * DY)
    ]
    coef3 = [
        DY * DY / (2 * (DX * DX + DY * DY)),
        DX * DX / (2 * (DX * DX + DY * DY)),
        -(DX * DX * DY * DY) / (2 * (DX * DX + DY * DY))
    ]
    coef4 = [
        - DT / (2 * DX),
        - DT / (2 * DY)
    ]

    velocity_kernels = {}
    poisson_kernels = [{}, {}]
    set_temporary_velocity_kernel(u_w1, v_w1, u_w2, v_w2, coef1, velocity_kernels)
    set_poisson_kernel(u_w2, v_w2, p_w1, p_w2, s, coef2, coef3, poisson_kernels[0])
    set_poisson_kernel(u_w2, v_w2, p_w2, p_w1, s, coef2, coef3, poisson_kernels[1])
    set_next_velocity_kernel(u_w2, v_w2, p_w1, u_w1, v_w1, coef4, velocity_kernels)

    fig, ax = plt.subplots()
    u_for_plot = []
    v_for_plot = []
    u_for_plot.append(u_w1.get())
    v_for_plot.append(v_w1.get())
    x, y = vp.linspace(0, LX, NX), vp.linspace(0, LY, NY)
    xx, yy = vp.meshgrid(x, y)

    for ts in range(1, NT + 1):
        # temporary velocity
        u = velocity_kernels['temporary_u'].execute()
        v = velocity_kernels['temporary_v'].execute()
        bnd_velocity(u, v, u_w1, v_w1)
        # poisson
        poisson_kernels[0]['poisson_right_hand'].execute()
        for i in range(MAX_ITER_JACOBI):
            p = poisson_kernels[i % 2]['poisson_solve_p'].execute()
            p_tmp = p_w1 if i % 2 == 0 else p_w2
            bnd_pressure(p, p_tmp)
            err = vp.linalg.norm(p - p_tmp) / vp.linalg.norm(p)
            if err < TOL_JACOBI:
                break
        p_w1[...] = p
        # next velocity
        u = velocity_kernels['next_velocity_u'].execute()
        v = velocity_kernels['next_velocity_v'].execute()
        bnd_velocity(u, v, u_w2, v_w2)
        # keep values for plot
        if ts % PLOT_INTERVAL == 0:
            print(ts)
            u_for_plot.append(u.get())
            v_for_plot.append(v.get())

    def animate(i):
        draw(u_for_plot[i], v_for_plot[i], ax, i)

    def animation_init():
        cs = ax.imshow(vp.sqrt(u*u + v*v), vmin=0, vmax=2., cmap='cividis')
        plt.colorbar(cs, label='Speed', orientation='vertical')
        plt.xlabel("x[m]")
        plt.ylabel("y[m]")

    animation.FuncAnimation(
        fig,
        animate,
        interval=100,
        frames=int(NT / PLOT_INTERVAL + 1),
        repeat=False,
        init_func=animation_init
    ).save(
        "cfd.gif",
        writer='pillow'
    )


if __name__ == '__main__':
    assert OBJ_X_END > OBJ_X_BEGIN
    assert OBJ_Y_END > OBJ_Y_BEGIN
    cfd()
Simulation Result
The temporal change in speed of each grid point is shown below.
Appendix
Discrete Equations
The superscript indicates the time step, and the subscript indicates the x coordinate and y coordinate.
Equation (A):
\begin{eqnarray} u^{\star}_{i,j}=(1-\frac{2\Delta t}{Re\Delta x^2}-\frac{2\Delta t}{Re\Delta y^2})u^{n}_{i,j}- \\ \frac{\Delta t}{2\Delta x}u^{n}_{i,j}(u^{n}_{i+1,j}-u^{n}_{i-1,j})- \\ \frac{\Delta t}{2\Delta y}v^{n}_{i,j}(u^{n}_{i,j+1}-u^{n}_{i,j-1})+ \\ \frac{\Delta t}{Re\Delta x^2}(u^{n}_{i+1,j}+u^{n}_{i-1,j})+ \\ \frac{\Delta t}{Re\Delta y^2}(u^{n}_{i,j+1}+u^{n}_{i,j-1}) \end{eqnarray}
\begin{eqnarray} v^{\star}_{i,j}=(1-\frac{2\Delta t}{Re\Delta x^2}-\frac{2\Delta t}{Re\Delta y^2})v^{n}_{i,j}- \\ \frac{\Delta t}{2\Delta x}u^{n}_{i,j}(v^{n}_{i+1,j}-v^{n}_{i-1,j})- \\ \frac{\Delta t}{2\Delta y}v^{n}_{i,j}(v^{n}_{i,j+1}-v^{n}_{i,j-1})+ \\ \frac{\Delta t}{Re\Delta x^2}(v^{n}_{i+1,j}+v^{n}_{i-1,j})+ \\ \frac{\Delta t}{Re\Delta y^2}(v^{n}_{i,j+1}+v^{n}_{i,j-1}) \end{eqnarray}
where u is the x-axial velocity and v is the y-axial velocity.
Equation (B):
S^{n}_{i,j}=\frac{1}{2\Delta t\Delta x}(u^{\star n}_{i+1,j}-u^{\star n}_{i-1,j})+\frac{1}{2\Delta t \Delta y}(v^{\star n}_{i,j+1}-v^{\star n}_{i,j-1})
p^{n+1}_{i,j}=\frac{\Delta y^2(p^{n+1}_{i+1,j}+p^{n+1}_{i-1,j})+\Delta x^2(p^{n+1}_{i,j+1}+p^{n+1}_{i,j-1})-\Delta x^2\Delta y^2 S^{n}_{i,j}}{2(\Delta x^2 + \Delta y^2)}
where S is the right hand side of the Poisson equation.
Equation (C):
u^{n+1}_{i,j} = u^{\star}_{i,j}-\frac{\Delta t}{2\Delta x}(p^{n+1}_{i+1,j}-p^{n+1}_{i-1,j})
v^{n+1}_{i,j} = v^{\star}_{i,j}-\frac{\Delta t}{2\Delta y}(p^{n+1}_{i,j+1}-p^{n+1}_{i,j-1})